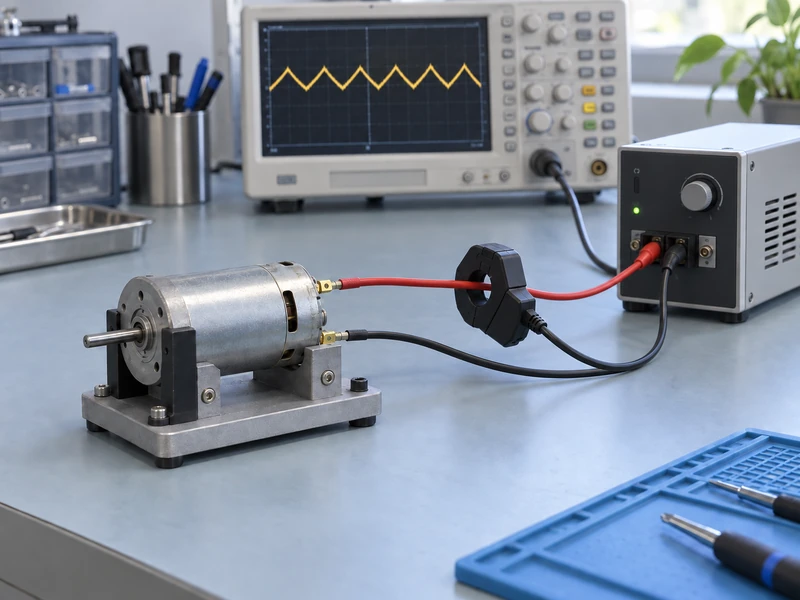
Coreless DC Motor PWM: How to Validate Current Ripple and Driver Compatibility
Match a coreless DC motor to its PWM drive by reviewing inductance, current ripple, measurement bandwidth and temperature under actual duty.
Match a coreless DC motor to its PWM drive by reviewing inductance, current ripple, measurement bandwidth and temperature under actual duty.
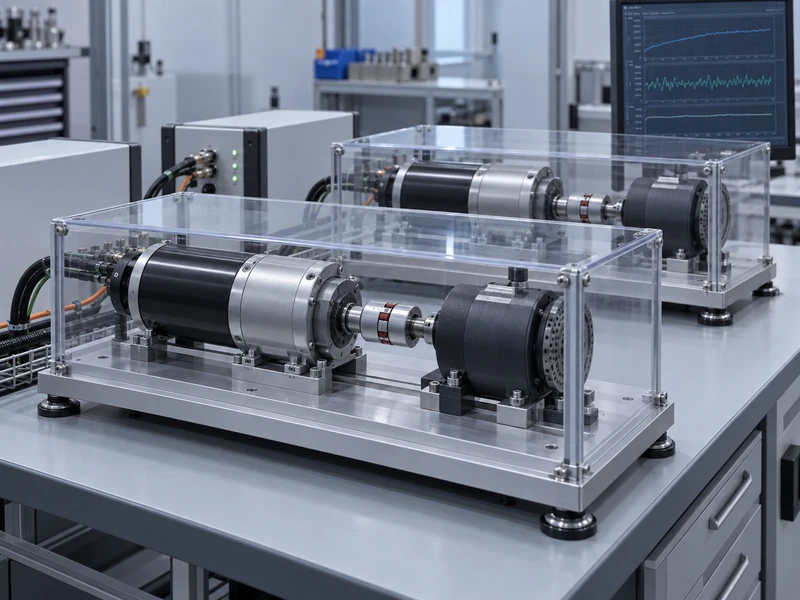
Define BLDC driver and controller behavior during voltage dips, then verify fault reporting, command handling and controlled restart.
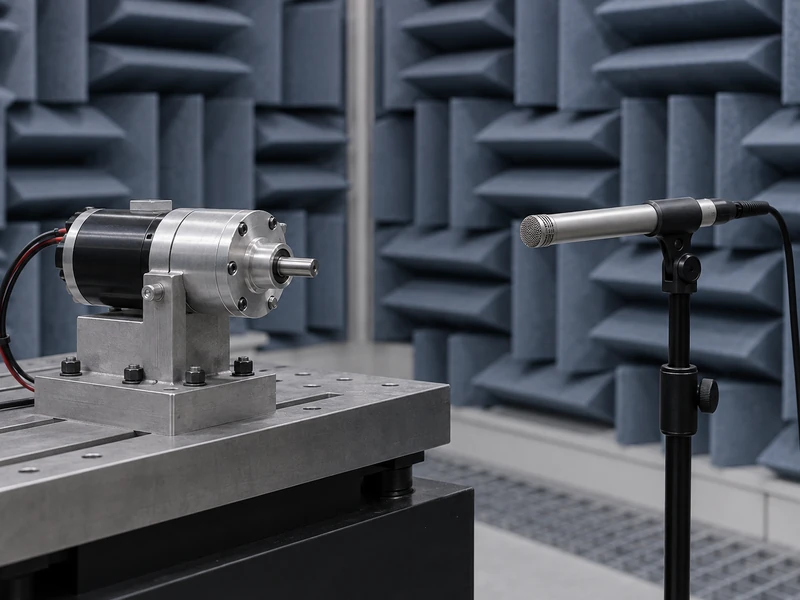
Create a reproducible gear motor acoustic acceptance method by controlling mounting, load, microphone position and background sound.
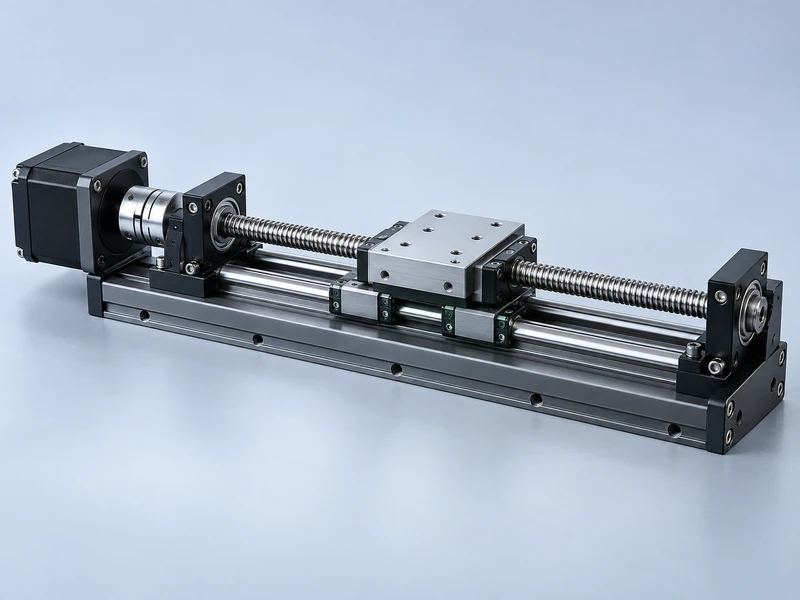
Check screw support, unsupported length, compression and speed before selecting the stroke and load of a linear stepper motor assembly.
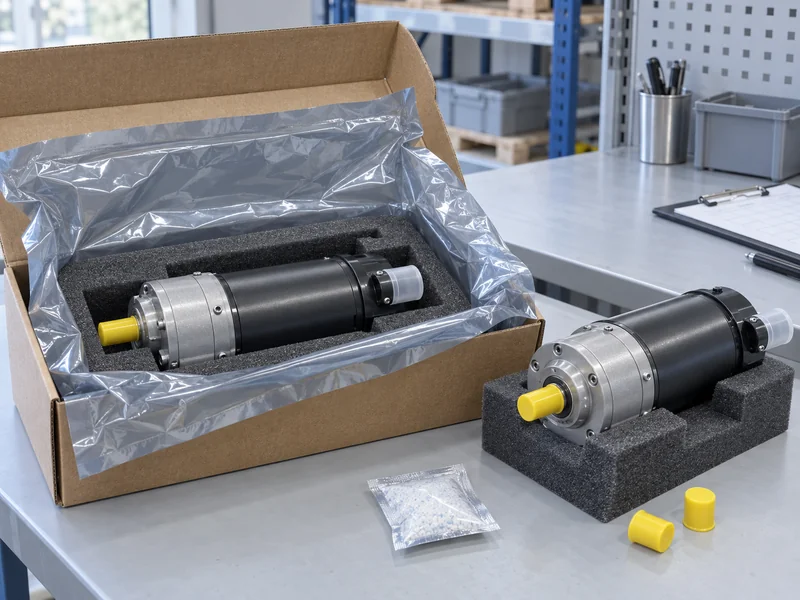
Plan packaging, storage records and release checks for unused gear motors without assuming an unopened carton guarantees installation readiness.
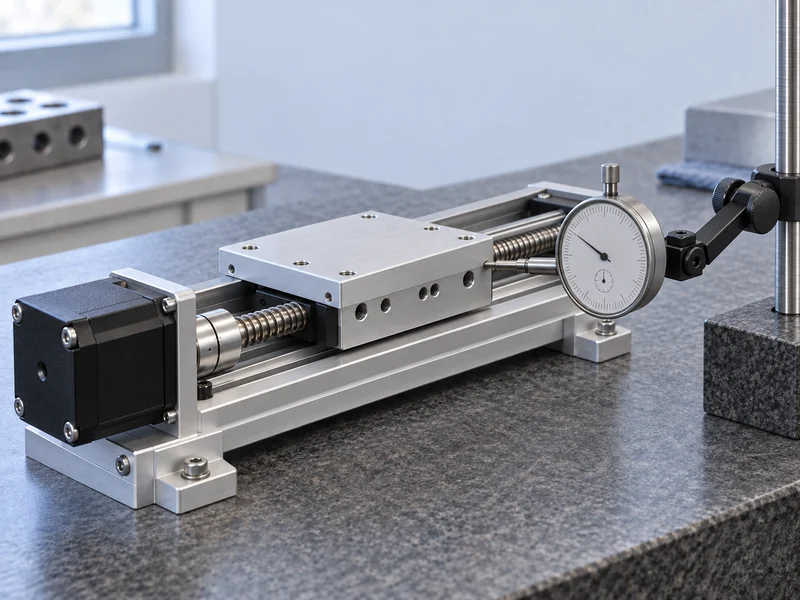
Learn how to test real stepper positioning error under load instead of treating microstep resolution as a guaranteed mechanical accuracy.
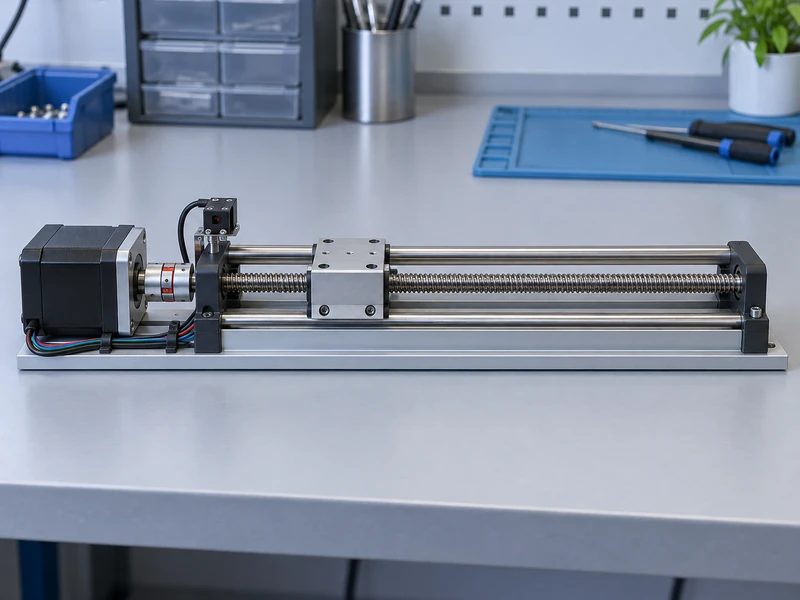
Specify a repeatable stepper homing cycle, separate sensor variation from axis errors, and agree on a practical verification method before release.
Validate reduced holding current through thermal, load and restart tests while keeping stepper position stable during production pauses.
Review cycle definitions, samples, failure criteria and acceleration assumptions before turning a gear motor endurance result into a life claim.
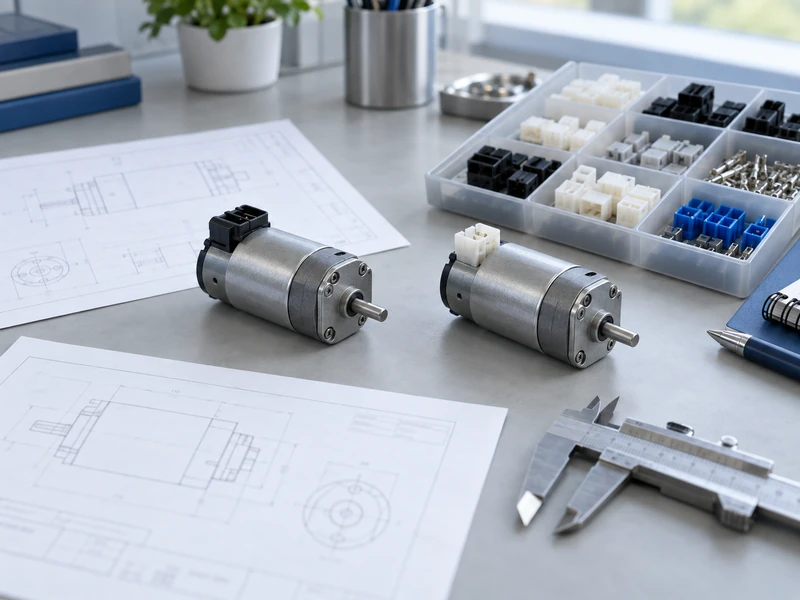
Control changes to motor windings, gear materials, connectors and software with a documented impact review, targeted tests and traceable release.
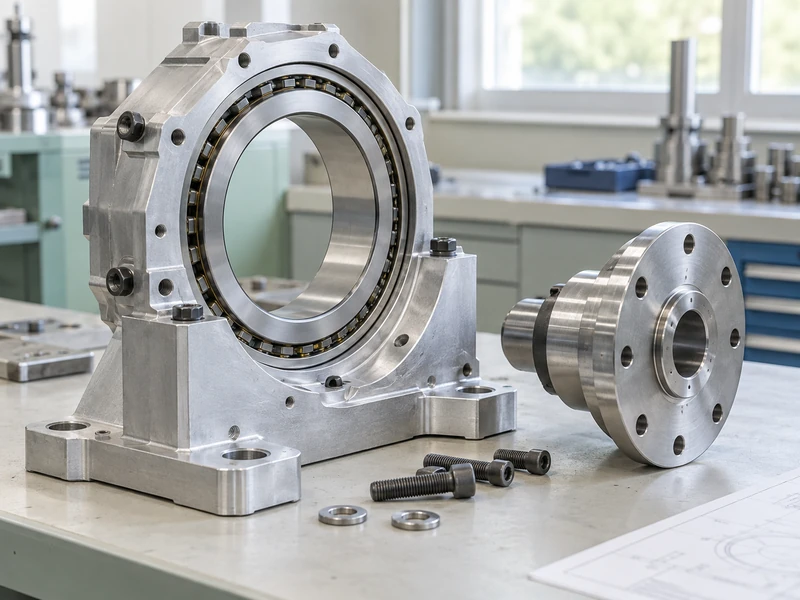
A robot joint’s torque rating does not establish whether its output can support the arm attached to it. Bearings and housing must also carry radial force, axial force, and overturning moment while maintaining acceptable stiffness and life. Specify those loads separately and trace how they reach the fixed structure before selecting the motor or gearbox.
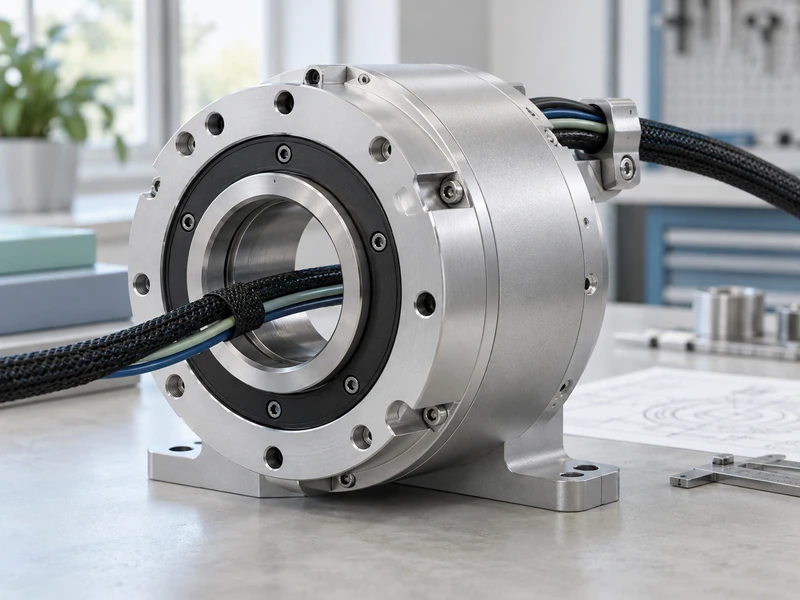
A hollow shaft robot joint needs a validated cable path, not just a bore large enough for loose wires. Check connector passage, bend and torsion limits, strain relief, moving clearances, signal integrity, and replacement access across the full motion range. Then test the assembled harness through representative cycles with the covers and constraints in place.